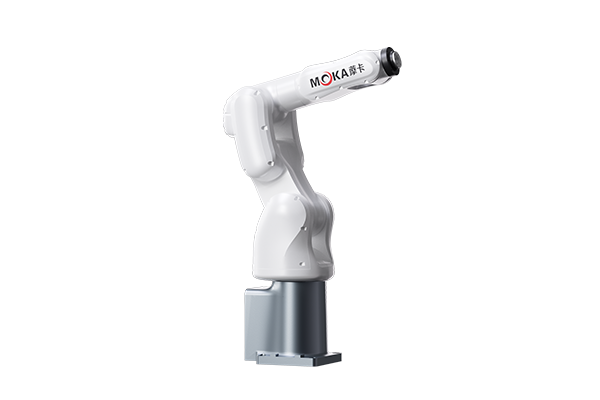
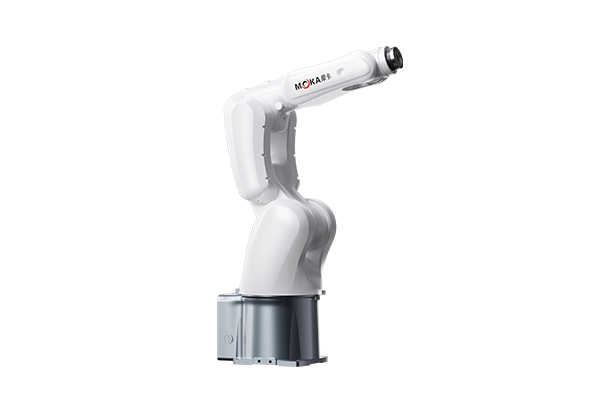
Material handling robots are industrial robots capable of performing automated material handling tasks. The earliest material handling robots appeared in the United States in 1960, with the Versatran and Unimate robots first used for material handling operations. Material handling refers to the process of gripping a workpiece with a device and moving it from one processing location to another. Transfer robots can be equipped with various end effectors to handle workpieces of different shapes and states, significantly reducing strenuous manual labor. They are widely applied in industries such as automotive parts manufacturing, vehicle assembly, machining, electronics and electrical equipment, rubber and plastics, wood and furniture manufacturing, as well as in sectors like pharmaceuticals, food, beverages, and chemicals for tasks including conveying, packaging, crating, handling, and palletizing. Some developed countries have established maximum limits for manual handling, requiring tasks exceeding these limits to be performed by material handling robots.
Material handling robots represent a cutting-edge technology in modern automation control, integrating disciplines such as mechanics, mechanical engineering, electrical/hydraulic/pneumatic systems, automatic control, sensor technology, microcontroller technology, and computer science. They have become a vital component of contemporary mechanical manufacturing systems. Their key advantage lies in executing programmed tasks with precision, combining the strengths of both human and machine in their structure and performance, particularly demonstrating artificial intelligence and adaptability.
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±170° | 480°/s |
| Axis 2L | -130° to +90° | 460°/s |
| Axis 3U | -60° to +205° | 520°/s |
| Axis 4R | ±190° | 560°/s |
| Axis 5B | ±120° | 560°/s |
| Axis 6T | ±360° | 880°/s |
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±170° | 300°/s |
| Axis 2L | -140° to +70° | 300°/s |
| Axis 3U | -75° to +200° | 400°/s |
| Axis 4R | ±190° | 550°/s |
| Axis 5B | ±130° | 560°/s |
| Axis 6T | ±360° | 975°/s |
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±170° | 300°/s |
| Axis 2L | -140° to +80° | 300°/s |
| Axis 3U | -75° to +200° | 400°/s |
| Axis 4R | ±190° | 550°/s |
| Axis 5B | ±130° | 560°/s |
| Axis 6T | ±360° | 975°/s |
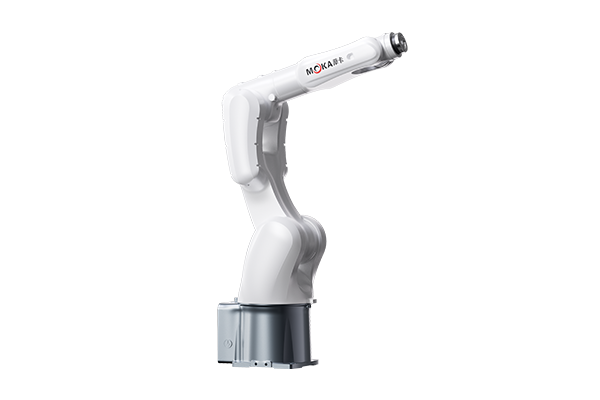
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±180° | 202°/s |
| Axis 2L | +98° to -160° | 212°/s |
| Axis 3U | +200° to -80° | 270°/s |
| Axis 4R | ±200° | 470°/s |
| Axis 5B | ±130° | 405°/s |
| Axis 6T | ±360° | 650°/s |
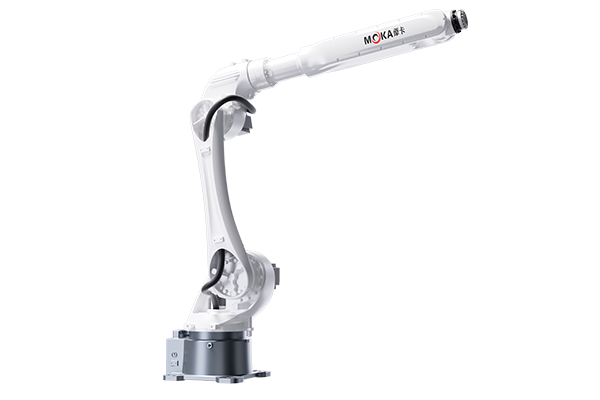
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±180° | 202°/s |
| Axis 2L | +98° to -160° | 211°/s |
| Axis 3U | +200° to -80° | 234°/s |
| Axis 4R | ±200° | 470°/s |
| Axis 5B | ±130° | 405°/s |
| Axis 6T | ±360° | 535°/s |
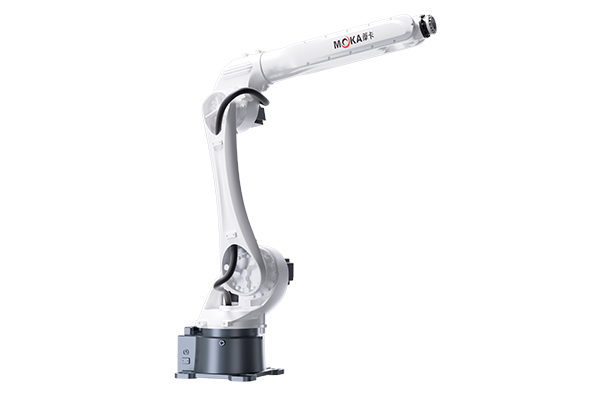
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±180° | 202°/s |
| Axis 2L | +98° to -160° | 211°/s |
| Axis 3U | +200° to -80° | 210°/s |
| Axis 4R | ±200° | 420°/s |
| Axis 5B | ±125° | 285°/s |
| Axis 6T | ±360° | 410°/s |
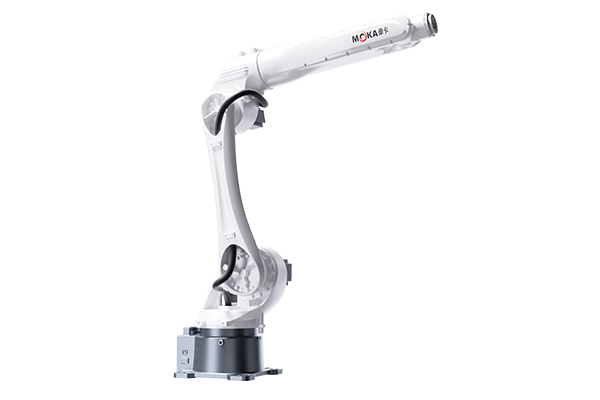
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±180° | 120°/s |
| Axis 2L | +60° to -80° | 110°/s |
| Axis 3U | +95° to -80° | 115°/s |
| Axis 4R | ±210° | 190°/s |
| Axis 5B | ±125° | 185°/s |
| Axis 6T | ±360° | 280°/s |
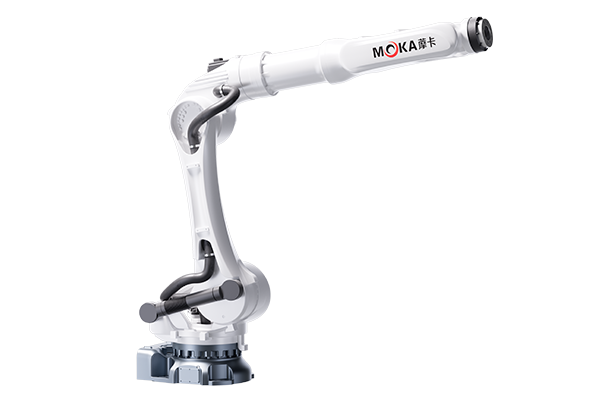
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±180° | 120°/s |
| Axis 2L | +60° to -80° | 110°/s |
| Axis 3U | +95° to -80° | 115°/s |
| Axis 4R | ±210° | 190°/s |
| Axis 5B | ±125° | 150°/s |
| Axis 6T | ±360° | 220°/s |
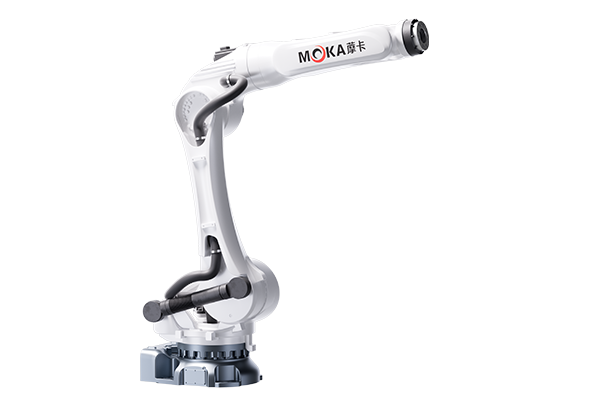
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±180° | 120°/s |
| Axis 2L | +60° to -80° | 110°/s |
| Axis 3U | +95° to -80° | 115°/s |
| Axis 4R | ±210° | 190°/s |
| Axis 5B | ±125° | 135°/s |
| Axis 6T | ±360° | 220°/s |
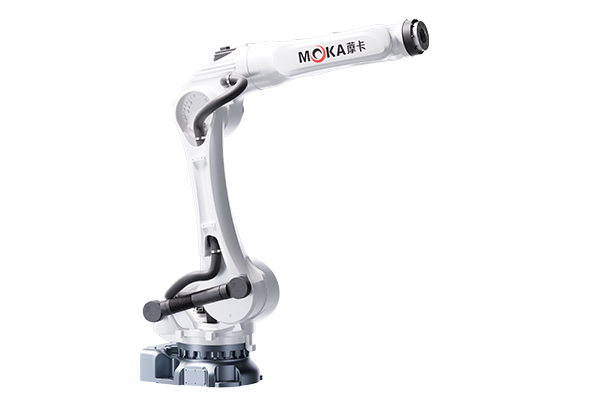
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±165° | 223°/s |
| Axis 2L | +92°to-150° | 223°/s |
| Axis 3U | +110°to-85° | 214°/S |
| Axis 4R | ±150° | 375°/S |
| Axis 5B | +20°to-200° | 412°/S |
| Axis 6T | ±360° | 600°/S |
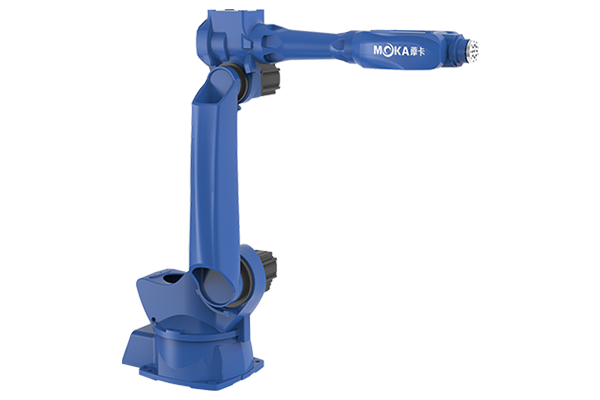
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±165° | 181°/s |
| Axis 2L | +92°to-150° | 181°/s |
| Axis 3U | +110°to-85° | 190°/s |
| Axis 4R | ±150° | 375°/s |
| Axis 5B | +20°to-200° | 412°/s |
| Axis 6T | ±360° | 600°/s |
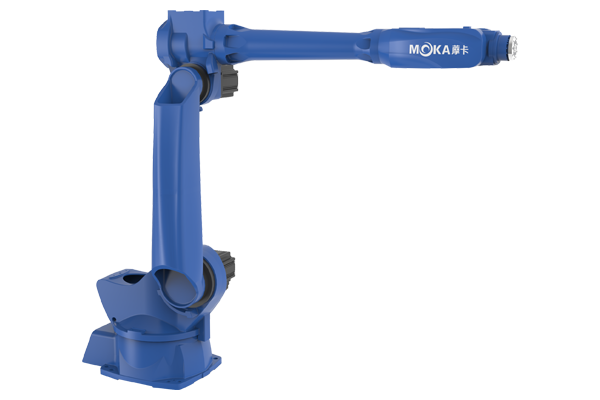
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±170° | 257°/s |
| Axis 2L | +80°to-145° | 223°/s |
| Axis 3U | +145°to-75° | 257°/s |
| Axis 4R | ±190° | 272°/s |
| Axis 5B | +20°to-220° | 275°/s |
| Axis 6T | ±360° | 540°/s |
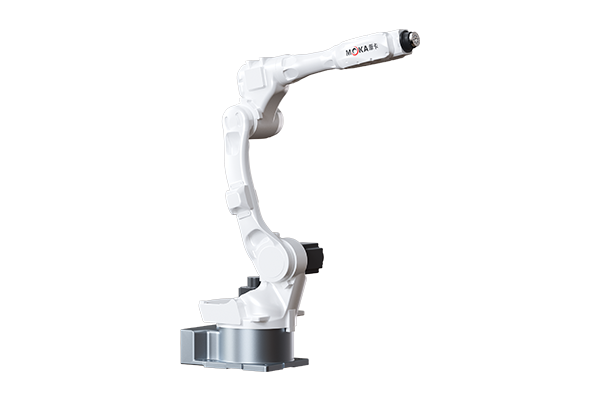
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±170° | 338°/s |
| Axis 2L | ±110° | 245°/s |
| Axis 3U | +70°to-90° | 300°/s |
| Axis 4R | ±200° | 262°/s |
| Axis 5B | ±120° | 376°/s |
| Axis 6T | ±360° | 600°/s |
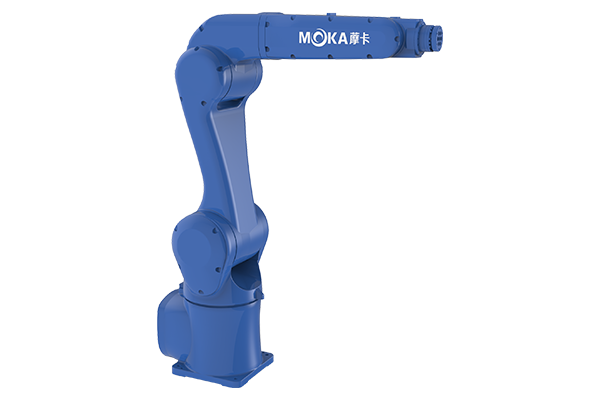
| Model: | MR60E-2680 |
| Axis | 6-axis |
Motion radius | 2680mm |
| Payload | 60KG |
| Protection class | J1,J2(IP56),J3,J4,J5,J6(IP67) |
| Installation type | Floor-standing/Bracket-mounted/Inverted |
| Power capacity | 19KVA |
| Input/output signals | Standard 16in/16 out,24VDC |
| Robot mass | 655KG |
| Repeatability | ±0.08mm |
| Applications | Loading and unloading, spraying, handling, cutting, grinding |
| Axis 4 R(N.m) | 210 |
| Axis 5 B(N.m) | 210 |
| Axis 6T(N.m) | 130 |
| Built-in air duct | Φ8/10 |
| Use environment | Temperature: 0–45°C Humidity: 20–80% RH (non-condensing) Vibration acceleration: ≤4.9 m/s² (0.5G) Altitude: ≤1000 m |
| Installation environment | No flammable or corrosive gases or liquids; no splashing water; minimal oil and dust; away from electromagnetic fields; away from magnetic fields. |
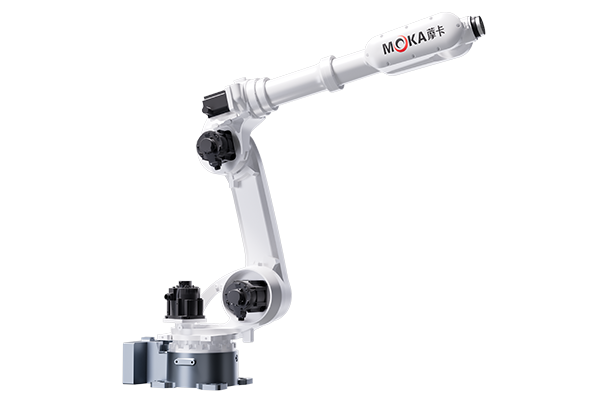
| Motion Parameters: | ||
| Axis | Range Of Motion | Movement Speed |
| Axis 1S | ±165° | 214°/s |
| Axis 2L | +90°to-120° | 149°/s |
| Axis 3U | +140°to-70° | 175°/s |
| Axis 4R | ±190° | 378°/s |
| Axis 5B | +30°to-210° | 285°/s |
| Axis 6T | ±360° | 370°/s |
| Dimensions | 850(W)*550(D)*920(H)mm(withprotrusions) |
| Approximate weight | 170kg |
| Cooling method | Natural cooling |
| Input power | 3PH 380VAC,50/60Hz |
| Grounding | Industrial Grounding (Specialized grounding with resistance below 100Ω) |
| Input output signal | Commonsignals:16digitalinputs,16digitaloutputs |
| Position control | Serialcommunication EtherCAT,TCP/IP |
| Memory capacity | JOB:200000 steps.Robot instructions:10000.(200MB) |
| LAN(communication) | EtherCAT(1),TCP/IP(1) |
| Serialinterface | RS485(1),RS422(1),RS232(1),CAN(1),USB(1) |
| Control mode | Software Servo <Position Control> |
| Drive unit | AC servo(6 axis),optional external axis |
| Temperature | 0~+45℃(use),-20~+60℃(storage) |
| Humidity | 10~90%RH,no condensing |
| Altitude | Below 1000m elevation, above 1000m, the maximum ambient temperature decreases by 1% for every additional 100m. Maximum usable at 2000m. |
| Vibration | Below4.9m/S²(0.5G) |
| Installation environment | No flammable or corrosive gases or liquids; no dust, cutting fluids (including coolants), organic solvents, oil fumes, water, salts, chemicals, rust-preventive oils; no exposure to strong microwaves, ultraviolet rays, X-rays, or radiation. |
| Dimensions | 280(W)*220(D)*120(H) mm(with protrusions) |
| Gross weight | 0.6KG |
| Material | Reinforced plastic |
| Operation buttons | Select key, axis operation key, value/application key, key-operated mode switch key (teach mode, playback mode, remote mode), emergency stop key, enable key, 1 USB port |
| Display | 8-inch colorLCD.Touch screen 640×480 pixels |
| Protection class | IP54 |
| Cable length | Standard:5m.Optional:up to 15m. |
telephone:+86-19150197267
mobile:
email:
website:www.moka-robot-global.com
address:No. 19, Weisi Road, Jiujiang District, Wuhu City, Anhui Province