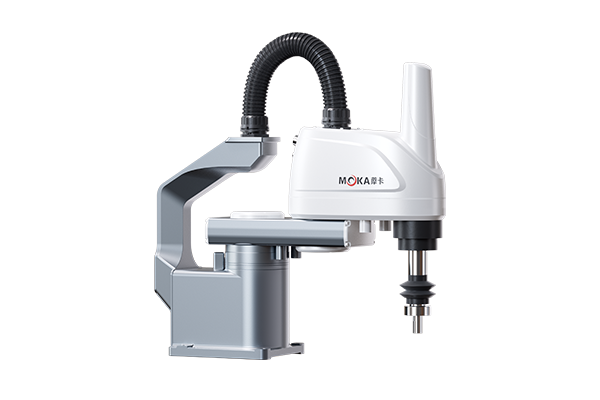
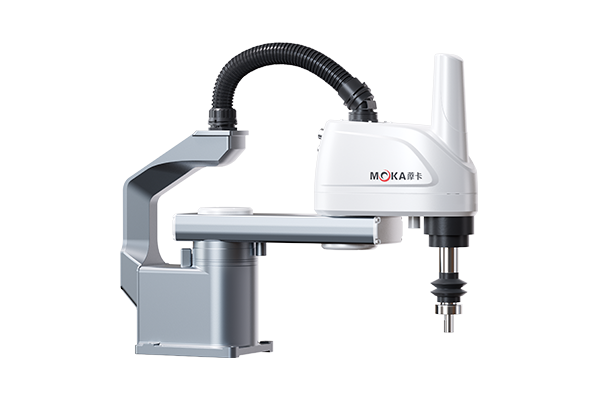
SCARA (Selective Compliance Assembly Robot Arm) is a special type of industrial robot with cylindrical coordinates.
SCARA robots feature three rotational joints with mutually parallel axes, enabling positioning and orientation within a plane. The fourth joint is a translational joint, facilitating end-effector movement perpendicular to the plane. The position of the wrist reference point is determined by the angular displacements φ1 and φ2 of the two rotary joints and the displacement z of the translational joint, i.e., p = f(φ1, φ2, z). This robot type features a lightweight structure and rapid response; for example, the Adept1 SCARA robot achieves speeds up to 10 m/s, several times faster than typical articulated robots. It is most suitable for planar positioning and vertical assembly tasks.
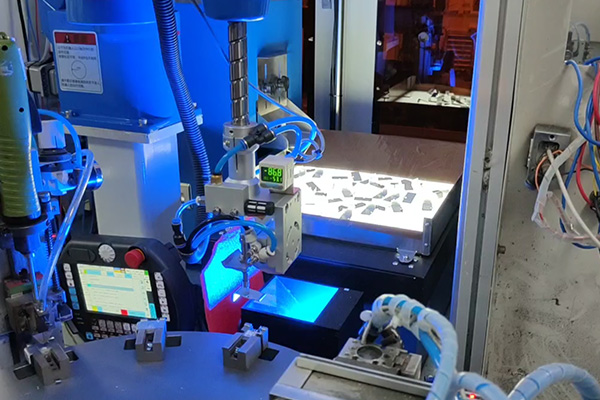
SCARA systems exhibit compliance in the x and y directions while maintaining high rigidity along the Z-axis. This characteristic makes them particularly well-suited for assembly tasks, such as inserting a round-headed pin into a circular hole. Consequently, SCARA systems were initially deployed extensively for assembling printed circuit boards and electronic components. Another defining feature of SCARA is its serial two-bar linkage structure, resembling a human arm. This allows it to extend into confined spaces for operations and then retract, making it well-suited for handling and picking up objects like integrated circuit boards.
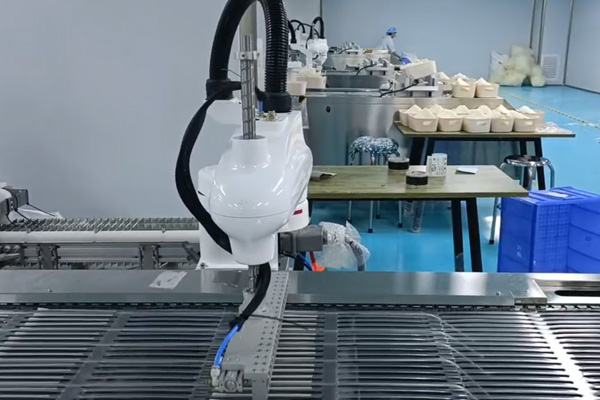
Today, SCARA robots are also widely used in the plastics industry, automotive industry, electronics manufacturing, pharmaceutical industry, and food processing industry. Their primary functions involve part handling and assembly tasks.
SCARA robots have only four axes, which constrain their range of motion and reduce their deviation. Their error is equivalent to one-quarter of a human hair.
Lightweight and compact SCARA robots enable rapid picking in confined spaces, making them ideal for applications with limited space such as 3C electronics, small appliances, and food packaging.
Because it moves along a horizontal axis, its motion is highly flexible, making it capable of handling tasks such as picking up, sorting, palletizing, and boxing small items, as well as transporting, stacking, and organizing materials.
It is one of the fastest types of industrial robots in the industry. Compared to other industrial robot types, it reduces cycle times, achieving cycle times as low as approximately 0.3 seconds. Even during prolonged periods of use, its speed remains unaffected.
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±120° | J1+J2 5950mm/s |
| Axis 2L | ±120° | J1+J2 5950mm/s |
| Axis 3U | 150mm | 1200mm/s |
| Axis 4R | ±360° | 880°/s |
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±120° | J1+J2 5950mm/s |
| Axis 2L | ±120° | J1+J2 5950mm/s |
| Axis 3U | 150mm | 1200mm/s |
| Axis 4R | ±360° | 880°/s |
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±135° | J1+J2 7380mm/s |
| Axis 2L | ±145° | J1+J2 7380mm/s |
| Axis 3U | 200mm | 1100mm/s |
| Axis 4R | ±360° | 880°/s |
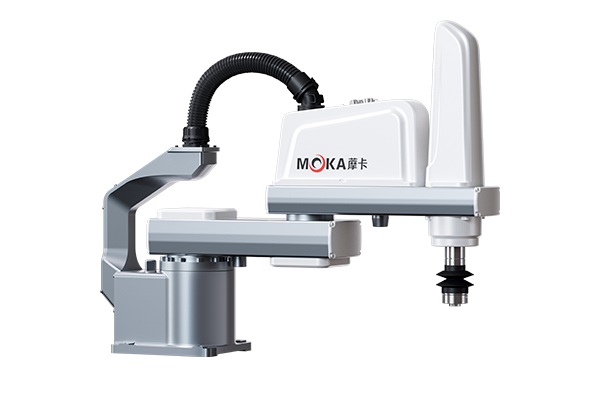
| Dimensions | 386(W)*445(D)*225(H)mm(no protrusions) |
| Approximate weight | 19kg |
| Cooling method | Direct cooling |
| Input power | Single-phase 220V 50/60Hz |
| Grounding | Industrial Grounding (Specialized grounding with resistance below 100Ω) |
| Input output signal | General-purpose signal: 16 inputs, 16 outputs (16-in, 16-out) |
| Position control | Serial Communication Protocol EtherCAT.TCP/IP |
| Memory capacity | JOB: 200,000 steps, 10,000 robot commands (200MB total) |
| LAN(communication) | EtherCAT (1) TCP/IP (1) |
| Control mode | Software Servo <Position Control> |
| Temperature | 0~+45℃(use),-20~+60℃(storage) |
| Drive unit | AC Servo Motor Servo Package (4-axis total) |
| Serial Port Interface | RS232/RS422/RS485 (one) RS232 (one) RJ45 Ethernet ports (three) |
| Humidity | 10% to 90% (non-condensing) |
| Vibration | Below4.9m/S²(0.5G) |
| Altitude | Below 1000m elevation, above 1000m, the maximum ambient temperature decreases by 1% for every additional 100m. Maximum usable altitude is 2000m. |
| Installation environment | Free from dust, cutting fluids (including coolants), organic solvents, oil fumes, water, salts, chemicals, rust-preventive oils, and exposure to strong microwaves, ultraviolet rays, X-rays, or radiation. |
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±135° | J1+J2 8100mm/s |
| Axis 2L | ±150° | J1+J2 8100mm/s |
| Axis 3U | 200mm | 1100mm/s |
| Axis 4R | ±360° | 880°/s |
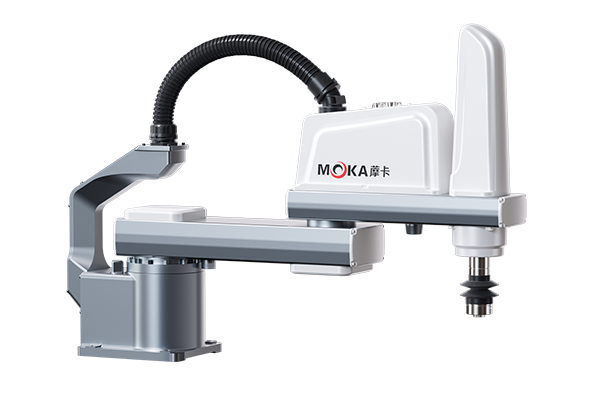
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±135° | J1+J2 9580mm/s |
| Axis 2L | ±150° | J1+J2 9580mm/s |
| Axis 3U | 200mm | 1100mm/s |
| Axis 4R | ±360° | 880°/s |
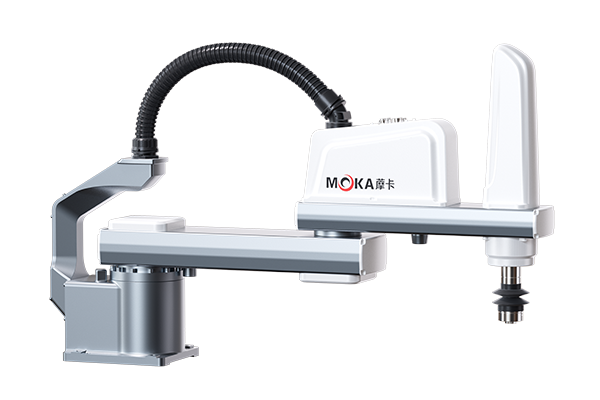
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±135° | J1+J2 10927.2mm/s |
| Axis 2L | ±150° | J1+J2 10927.2mm/s |
| Axis 3U | 200mm | 1100mm/s |
| Axis 4R | ±360° | 880°/s |
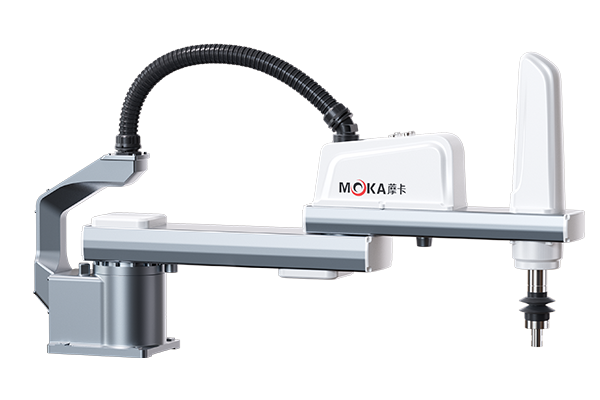
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±135° | J1+J2 9210mm/s |
| Axis 2L | ±150° | J1+J2 9210mm/s |
| Axis 3U | 420mm | 2020mm/s |
| Axis 4R | ±360° | 720°/s |
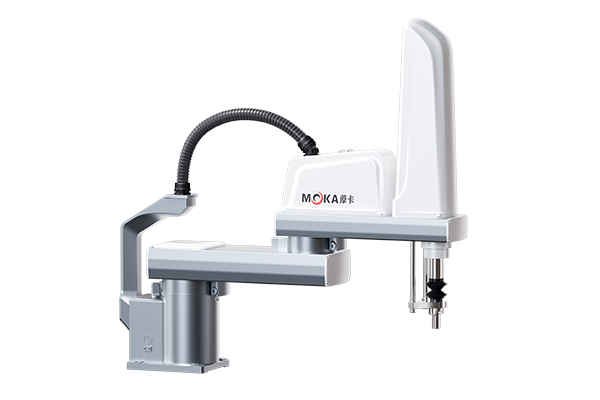
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±135° | J1+J2 10360mm/s |
| Axis 2L | ±150° | J1+J2 10360mm/s |
| Axis 3U | 420mm | 2020mm/s |
| Axis 4R | ±360° | 720°/s |
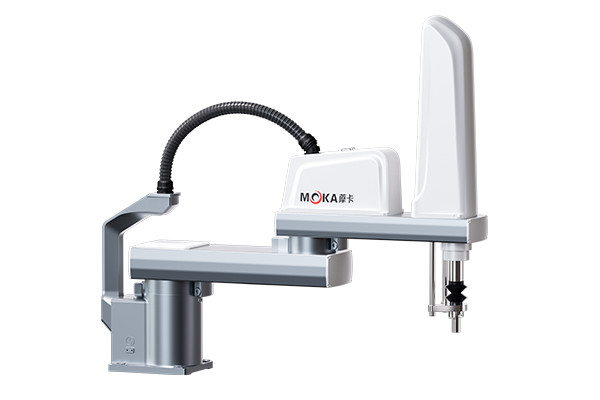
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±135° | J1+J2 11520mm/s |
| Axis 2L | ±150° | J1+J2 11520mm/s |
| Axis 3U | 420mm | 2020mm/s |
| Axis 4R | ±360° | 720°/s |
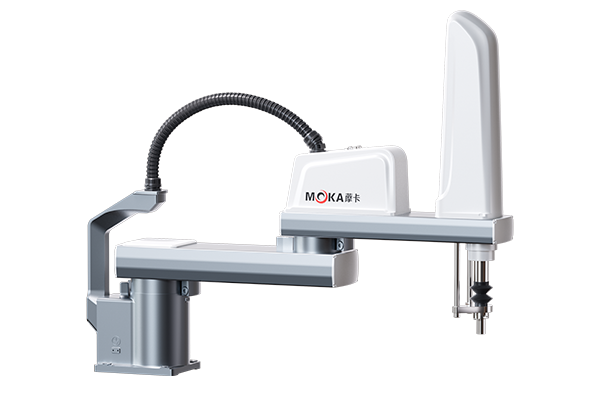
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±132° | 540°/s |
| Axis 2L | ±150° | 600°/s |
| Axis 3U | 220mm | 750°/s |
| Axis 4R | ±360° | 1717°/s |
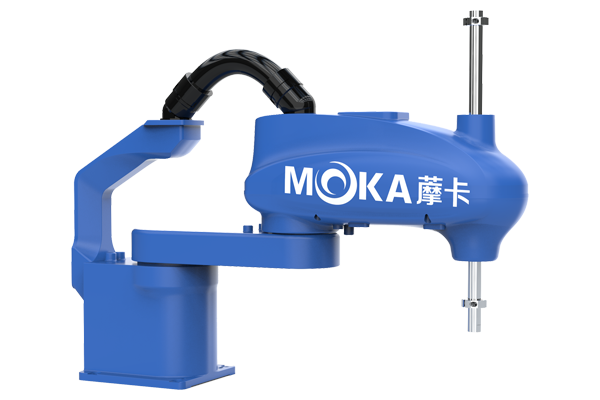
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±132° | 540°/s |
| Axis 2L | ±150° | 600°/s |
| Axis 3U | 220mm | 750°/s |
| Axis 4R | ±360° | 1717°/s |
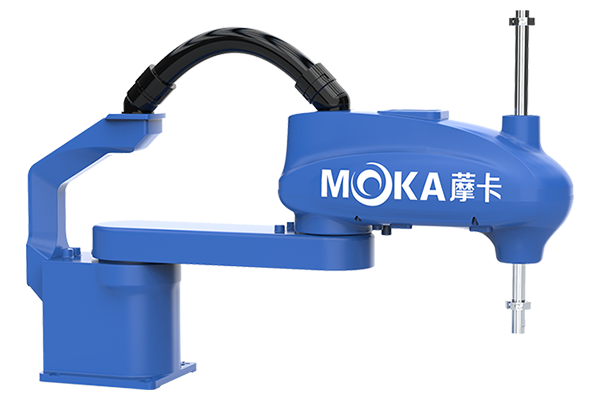
| Axis | Range Of Motion | Movement Speed |
|---|---|---|
| Axis 1S | ±132° | 540°/s |
| Axis 2L | ±150° | 600°/s |
| Axis 3U | 220mm | 750°/s |
| Axis 4R | ±360° | 1717°/s |
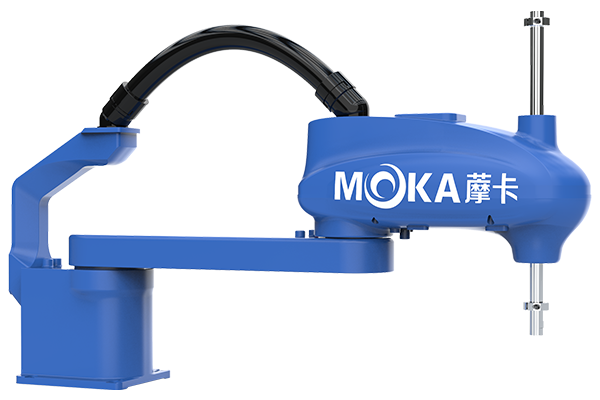

High-speed operation boosts production efficiency

Repeatability accuracy: ±0.02mm Deviation equivalent to just 1/4 of a human hair

Continuous operation without vibration

The exterior features streamlined curves, creating a visually smooth and aesthetically pleasing appearance.

Surface powder coating process, with a coating that is wear-resistant and corrosion-resistant.
telephone:+86-19150197267
mobile:
email:
website:www.moka-robot-global.com
address:No. 19, Weisi Road, Jiujiang District, Wuhu City, Anhui Province